proomt

Search

Search posts, papers, and topics

All posts

Simon Willison1 min readintro
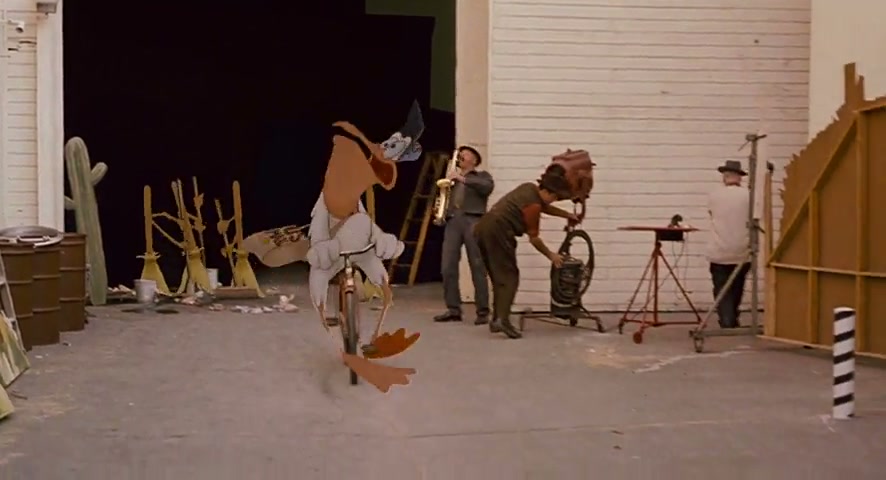
The Creative Spirit of Who Framed Roger Rabbit

Summary

A brief, non‑technical blog post reminiscing about a practical‑effects gag in *Who Framed Roger Rabbit* – a pelican animated on a real bicycle, with wheels filled with water for stability and guided by a cable.

  • The post is a nostalgic description of a movie stunt, not an engineering analysis.
  • No technical details, code, or design rationale are provided.

None for software engineering practice; the content is purely cultural.

2/10
Related reading

  1. The Shadows Lurking in the Equations – Underwater Islands

    The article introduces FuzzyGraph, a web tool that visualizes equations as error heatmaps (fuzzy/non‑binary mode) instead of the classic binary “exact‑equals” plots. By showing regions of high error (black‑hole shadows) and low error (underwater islands), the author argues that fuzzy graphs reveal mathematical features invisible to conventional graphing tools.

    Hacker News front pagegods.art4 minHN7013
  2. PhysStream: Streaming Physics-Grounded Video Generation with Structured Scene Memory and Fine-Grained Motion Control

    PhysStream introduces a two‑stage autoregressive video generator that uses online‑derived positional and tracking maps (structured scene memory) and sparse velocity‑increment signals to enable fine‑grained, physics‑grounded control of multi‑object tabletop scenes. It cuts motion distribution error by 33 % and trajectory error by 12 % versus strong baselines, and wins 85 % of human preference test…

    Hugging Face Daily Papersarxiv.org1 minpaper
  3. DeformSmith: Physics Harness-Guided Hierarchical Generation of Deformable Assets for Robot Manipulation

    DeformSmith is a framework that generates physically plausible deformable assets for robot manipulation from a text prompt or a single image, using a hierarchical construction process guided by a shared physics harness. It outperforms prior baselines in visual fidelity and physical realism while also producing interaction data for downstream tasks.

    Hugging Face Daily Papersarxiv.org1 minpaper
  4. VABench: Measuring Embodied Spatial Intelligence through Visual Demonstrations, Active Perception, and Metric Control

    VA‑Bench is a new benchmark that evaluates general‑purpose multimodal LLMs on the full observe‑reason‑act‑revise loop in embodied robotics, using RGB demonstrations, active camera control, and metric Cartesian commands. The best model reaches 53.9% average task success, showing active perception helps but long‑horizon tasks remain unsolved.

    Hugging Face Daily Papersarxiv.org1 minpaper