Related reading
Quiz: Using the Claude API in Python
A 6‑question interactive quiz that checks knowledge of the Claude API Python SDK: installing the `anthropic` package, sending messages with `client.messages.create()`, using system prompts, and extracting structured data via Pydantic.
Real Pythonrealpython.com1 minArticle: Architecting Secure and Scalable Facial Verification Systems
A real‑world post‑mortem of a high‑volume face verification service that moved from a naïve synchronous API to an async, layered pipeline (edge validation, preprocessing, decoupled detection/verification, decision engine) to achieve 8.5k rpm, p99 < 1.8 s, 30 % cost savings, and strict privacy controls.
InfoQinfoq.com15 minDeformSmith: Physics Harness-Guided Hierarchical Generation of Deformable Assets for Robot Manipulation
DeformSmith is a framework that generates physically plausible deformable assets for robot manipulation from a text prompt or a single image, using a hierarchical construction process guided by a shared physics harness. It outperforms prior baselines in visual fidelity and physical realism while also producing interaction data for downstream tasks.
Hugging Face Daily Papersarxiv.org1 minpaperQuiz: Build a Python Turtle Game: Space Invaders Clone
This page is an 11‑question quiz that checks your understanding of the Real Python tutorial on building a Space Invaders clone with the built‑in turtle module. It revisits screen setup, sprite drawing, input handling, game loop, collision detection, and frame‑rate pacing.
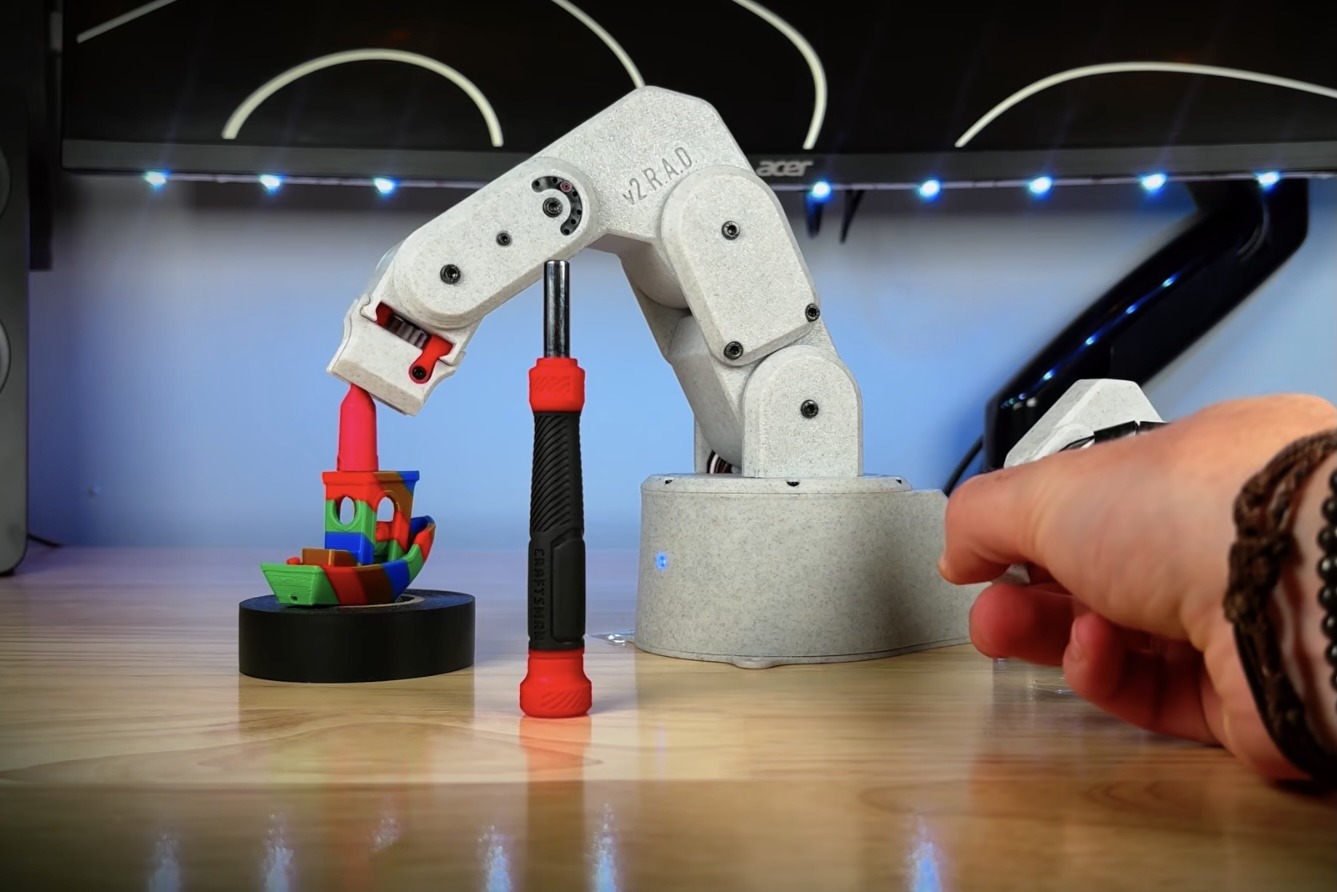
Real Pythonrealpython.com1 minRedesigning a popular robotic arm
Arduino’s blog spotlights a community‑built robotic arm that’s been mechanically redesigned for cheaper parts, easier 3‑D printing, and better performance. The arm uses a Nano ESP32 to read potentiometer‑based puppet‑style input and drive servos via a driver board, with belt‑driven wrist and rack‑and‑pinion gripper upgrades.
Arduino Blogarduino.cc1 minBuild your own smart doorbell and protect your privacy – in one hour, with Massimo Banzi
Arduino’s blog promotes a live build where you assemble a smart doorbell on an UNO Q board that runs vision locally. The focus is on privacy by keeping data on‑device, but the post offers no technical depth.
Arduino Blogarduino.cc1 min