Arduino BlogArduino Team1 min readintermediate
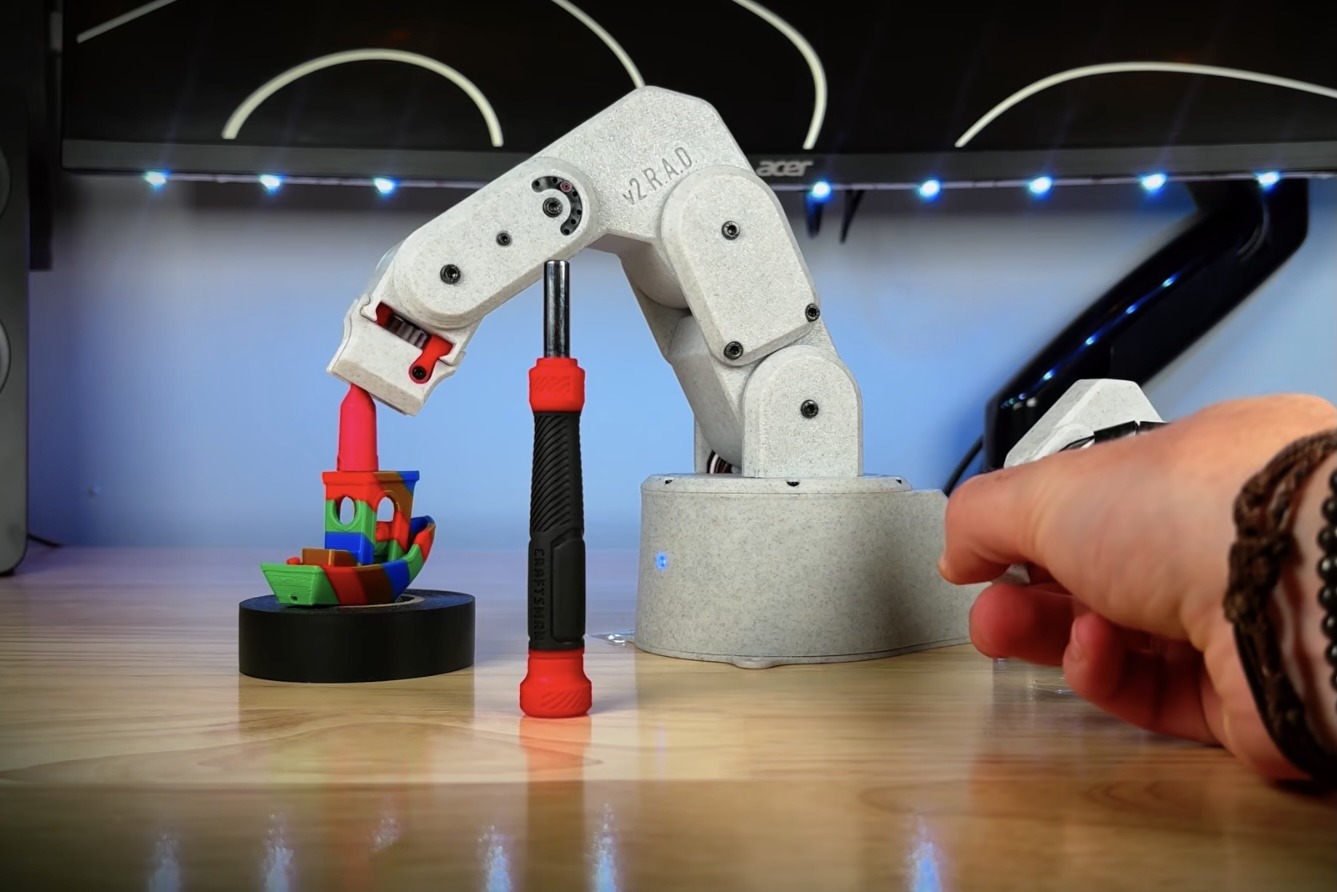
Redesigning a popular robotic arm
Summary
Arduino’s blog spotlights a community‑built robotic arm that’s been mechanically redesigned for cheaper parts, easier 3‑D printing, and better performance. The arm uses a Nano ESP32 to read potentiometer‑based puppet‑style input and drive servos via a driver board, with belt‑driven wrist and rack‑and‑pinion gripper upgrades.
- Puppet‑style control maps potentiometer voltage directly to joint angles, simplifying the control loop.
- Mechanical redesign focuses on 3‑D‑printable parts, belt drive for wrist, and rack‑and‑pinion for gripper to improve precision and reduce cost.
- Arduino Nano ESP32 serves as the central controller, handling analog input and PWM output to servos.
- All CAD files are publicly available for hobbyists to print and assemble.
Shows a practical, low‑cost approach to building a 6‑DOF robotic arm with intuitive control, useful for education, prototyping, or hobby projects where budget and accessibility matter.
5/10